Space Exploration and Sustained Operations Beyond Earth
A technically grounded forum convening the space and terrestrial robotics communities around the challenges of exploration and sustained operations beyond Earth — from lunar and planetary surfaces to orbit.
Overview
Robotic systems are becoming central to the next decade of space activity: NASA's Artemis lunar campaign and broader Moon-to-Mars architecture; the growing roles of ESA, JAXA, and other agencies in lunar exploration infrastructure; and expanding commercial capabilities beyond Earth orbit all demand higher levels of autonomy, adaptability, and human-robot teaming. In parallel, terrestrial robotics is advancing rapidly through an explosion in AI capabilities, cheaper and better sensors and compute, and improved sim-to-real transfer — creating a timely opportunity to translate these advances into more capable and robust space robotic systems.
This workshop convenes the space robotics and terrestrial robotics communities around the challenges and opportunities that most directly impact exploration and sustained operations beyond Earth. It focuses on robotic systems that support lunar and planetary missions, astronaut assistance, surface infrastructure, logistics, and other mission-enabling capabilities in extreme environments.
Compared to prior space robotics events, this workshop is framed around the broader challenge of enabling exploration and sustained operations beyond Earth, rather than a single domain or technical area. It brings together multiple domains under one umbrella, with an applied emphasis on mission use, integration constraints, and validation.
Timeline
Extended: August 21st, 2026, 11:59 PM (AoE)
Invited Speakers
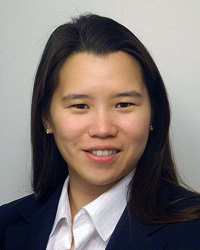
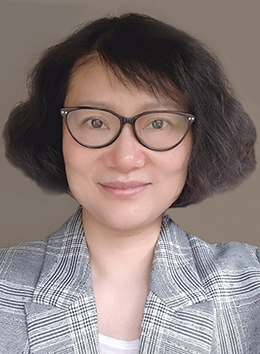
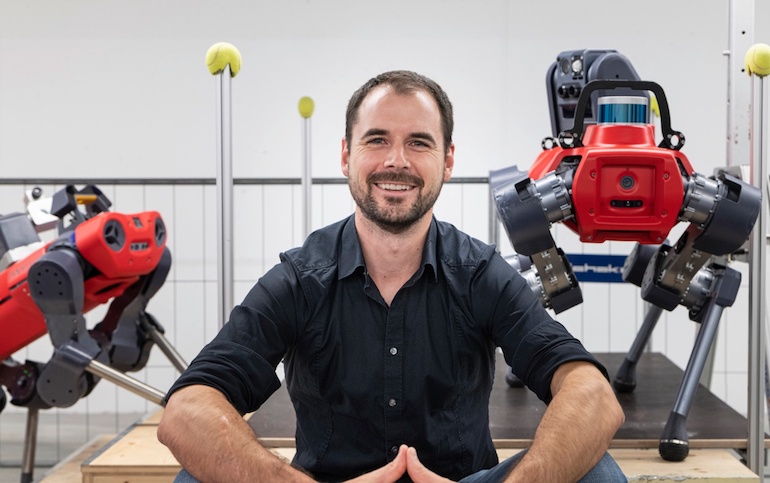
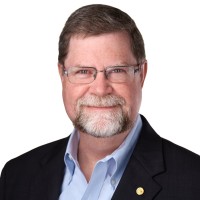
Agenda
All times are in Eastern Time (ET).
- Opening Remarks
8:30 – 8:35 AM Ignacio G. López-FrancosSETI Institute / UT Austin
- Keynote — "Similitude Techniques for Correlating Lunar Rover Performance with Earth Testing"
8:35 – 9:00 AMRob AmbroseTexas A&M University / NASA - Invited Talk — "From Constellation Coordination to Mission-Scale Digital Twins"
9:00 – 9:25 AMGiusy FalconeUniversity of Michigan - Invited Talk — "TRUSSES: Temporarily, Robots Unite to Surmount Sandy Entrapments, then Separate"
9:25 – 9:50 AMCynthia SungUniversity of Pennsylvania - Industry Lightning Talk — TBD
9:50 – 9:55 AMBrian YamauchiStarpath - Invited Talk — TBD
9:55 – 10:10 AMYuto NakanishiGITAI - Contributed Paper Spotlights (4 × 5-minute presentations)
10:10 – 10:30 AM - Coffee Break + Poster Session
10:30 – 11:00 AM - Invited Talk — "Lunar Leaper: A Mission to Investigate Lava Tubes on the Moon"
11:00 – 11:25 AMMarco HutterETH Zurich - Invited Talk — "AI Robotics for Sustainable Space Exploration"
11:25 – 11:50 AMYang GaoHong Kong University of Science and Technology - Panel Discussion — "Next-Gen Lunar Robotics: Building and Sustaining a Moon Base"
11:50 AM – 12:20 PMYuto NakanishiGITAIEmma ZemlerNASABrian YamauchiStarpathYashwanth NakkaGeorgia Tech - Awards + Closing Remarks
12:20 – 12:30 PM
Best Paper / Poster Awards + Closing
Accepted Submissions
Congratulations to all the authors whose work was selected! Thank you to everyone who submitted, and to our reviewers for their valuable feedback and dedication to maintaining the quality of the workshop.
Call for Contributions
The organizing committee invites high-quality contributions advancing robotics for exploration, operation, construction, and sustained activity beyond Earth. We invite extended abstracts (2–4 pages) on topics including but not limited to:
- Planetary surface mobility, manipulation, and loco-manipulation across wheeled, legged, aerial, and hybrid platforms
- Lunar surface logistics, construction, assembly, servicing, maintenance, and in-situ resource utilization (ISRU)
- In-space servicing, assembly, and manufacturing; orbital robotics; and IVA/EVA robotic assistance
- Multi-robot coordination and heterogeneous teams for distributed operations
- Machine perception, spatial intelligence, navigation, and mapping under degraded sensing and limited PNT
- Human-robot teaming, shared autonomy, and teleoperation under communication latency
- Robust autonomy, fault management, anomaly response, and assurance for learning-enabled systems
- Earth-independent autonomy under constrained compute, power, communications, and thermal resources
- Physical AI, embodied foundation models, and adaptive control for contact-rich tasks
- Sim-to-real transfer, digital twins, benchmarking, analog testing, and interoperable robotic interfaces
Submissions will be evaluated based on technical merit and innovation, relevance to space robotics and sustained operations beyond Earth, clarity of presentation, and potential impact on the field. All submissions will undergo double-blind peer review. Please anonymize your manuscript by removing author names and affiliations and avoiding identifying self-references.
The workshop is non-archival: accepted submissions will not appear in IEEE proceedings, and authors retain full rights to submit their work elsewhere. Work in progress and concurrently submitted work are welcome.
- Extended abstracts may be up to 4 pages, including references.
- Submissions must be in PDF format (up to 10 MB) and must follow the official IEEE RAS double-column template. You can find the templates on the official IEEE RAS template page or via the IROS 2026 call for papers guidelines.
- All submissions must be made through OpenReview. Here's the submission link.
- Authors of accepted submissions may optionally provide a 2–3 minute video presentation. Instructions will be provided after notification.
- Accepted submissions will be presented as posters. A selected subset will also be invited to give short oral presentations. Best Contribution* and Best Oral Presentation** awards will be presented at the workshop.
- Camera-ready versions of accepted submissions will be published on the workshop website. At least one author must register for the workshop and present the poster in person.
* Best Contribution recognizes the strongest technical work, based on the extended abstract, poster, and overall relevance to the workshop themes.
** Best Oral Presentation recognizes the strongest live communication among the selected oral presenters.
For submission-related questions, please contact the Program Chairs:
- Andres Mora: andres.moravargas@nasa.gov
- Pyojin Kim: pjinkim@gist.ac.kr
Expected Audience
The workshop targets researchers and practitioners working on planetary robotics and autonomy for extreme surface environments (Moon, Mars, and other planetary bodies), along with the broader IROS community developing enabling methods that translate to deep-space missions. Expected backgrounds include surface mobility and terramechanics, contact-rich manipulation and sampling, perception / localization / mapping under degraded sensing, planning and control for long-horizon autonomy, multi-robot and heterogeneous teaming, fault management and assurance, and human-robot teaming.
We explicitly engage the IEEE RAS Technical Committee on Space Robotics and closely related communities (Field Robotics, Robotic Vision, SLAM, Mobile Manipulation, Multi-Robot Systems, and HRI), as well as government agencies and the Pittsburgh-area robotics and space ecosystem (e.g., Astrobotic, Field.AI, and Carnegie Mellon University).
Organizers
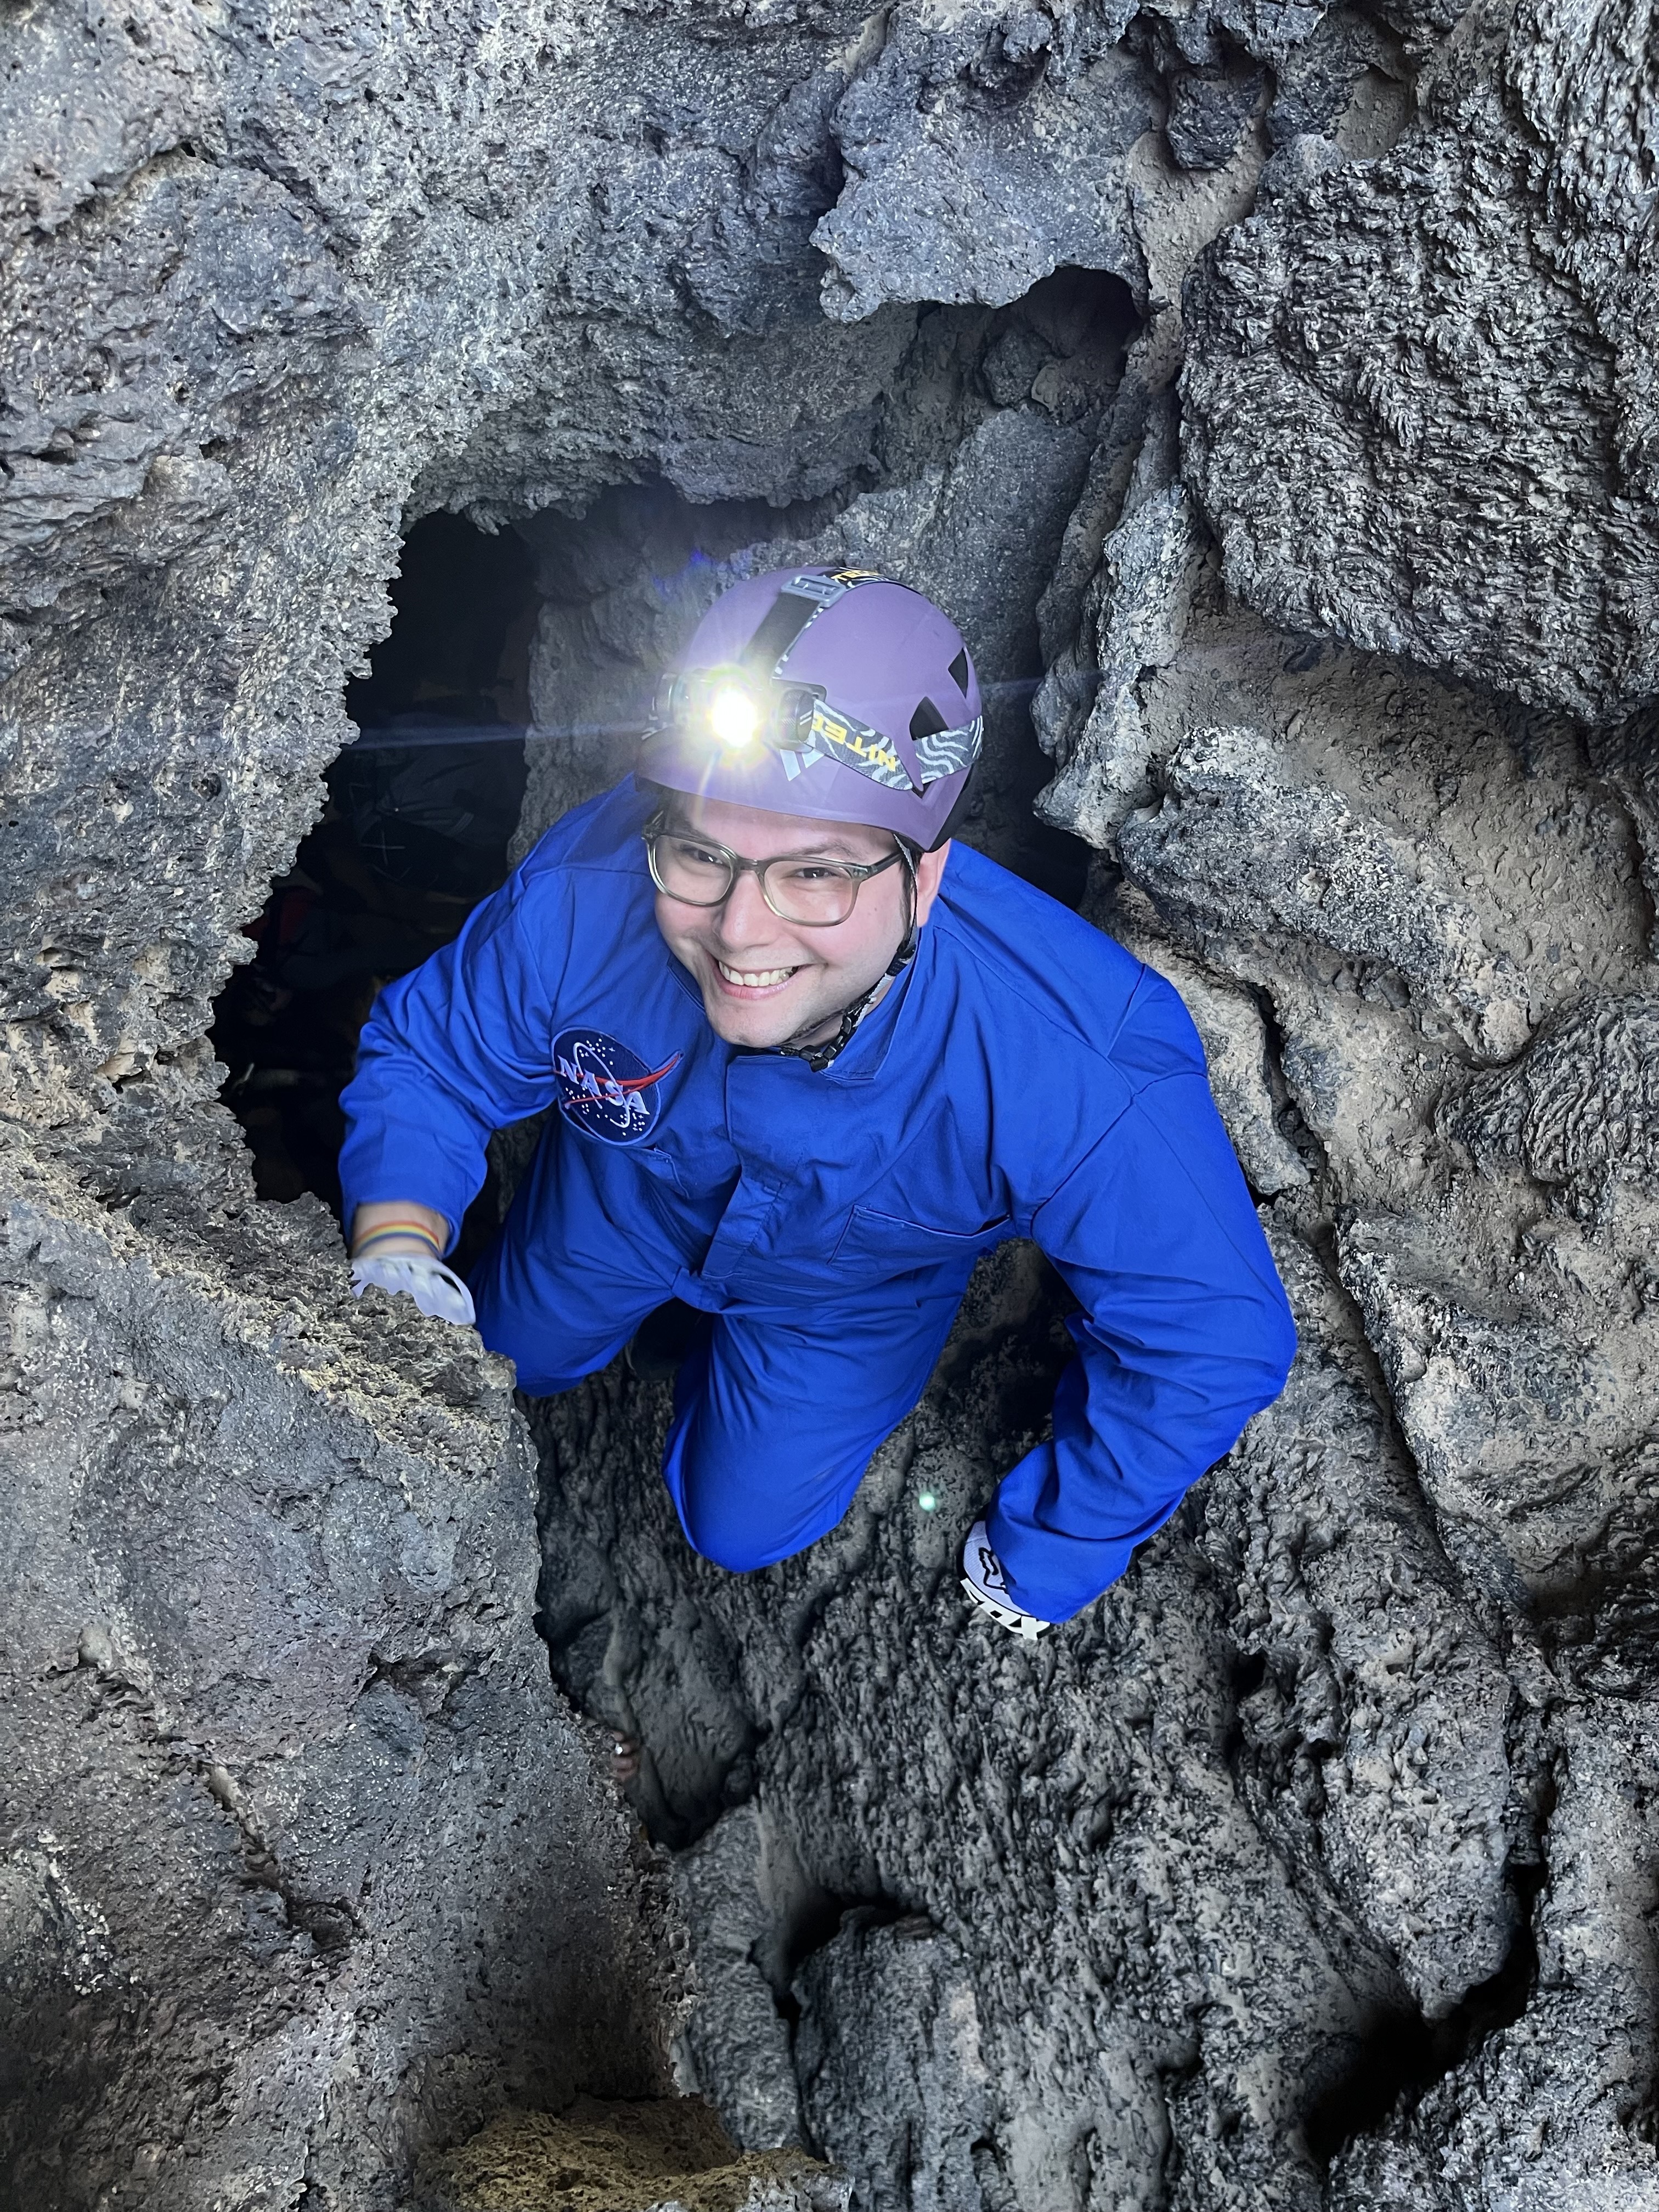
The Space Robotics Workshop is a volunteer-led effort by researchers and practitioners in robotics, autonomy, and AI from across academia, government, and industry.

Sponsors
We are grateful to the organizations whose support helps make the Space Robotics Workshop possible.
Contact
For sponsorship, participation, or other inquiries please contact hello@space-robots.org with the subject line SRW @ IROS 2026.